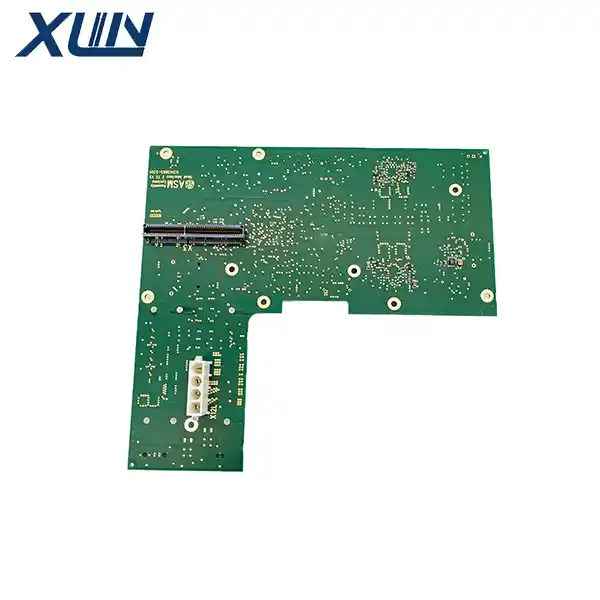
 It is responsible for power distribution between the CP20P2 placement head and the TX2i robotic arm, relaying CAN communication, and aggregating signals from various encoders and sensors located within the head.
Signal Routing and Distribution: Distributes commands from the main machine controller to the various actuators (motors, valves, and sensors) inside the placement head.
Power Supply and Status Monitoring: Provides operating voltage to the internal circuit boards of the placement head and uses LEDs or digital displays to provide feedback on fault conditions (such as power supply anomalies, emergency stops, motor overheating, or FPGA status).